
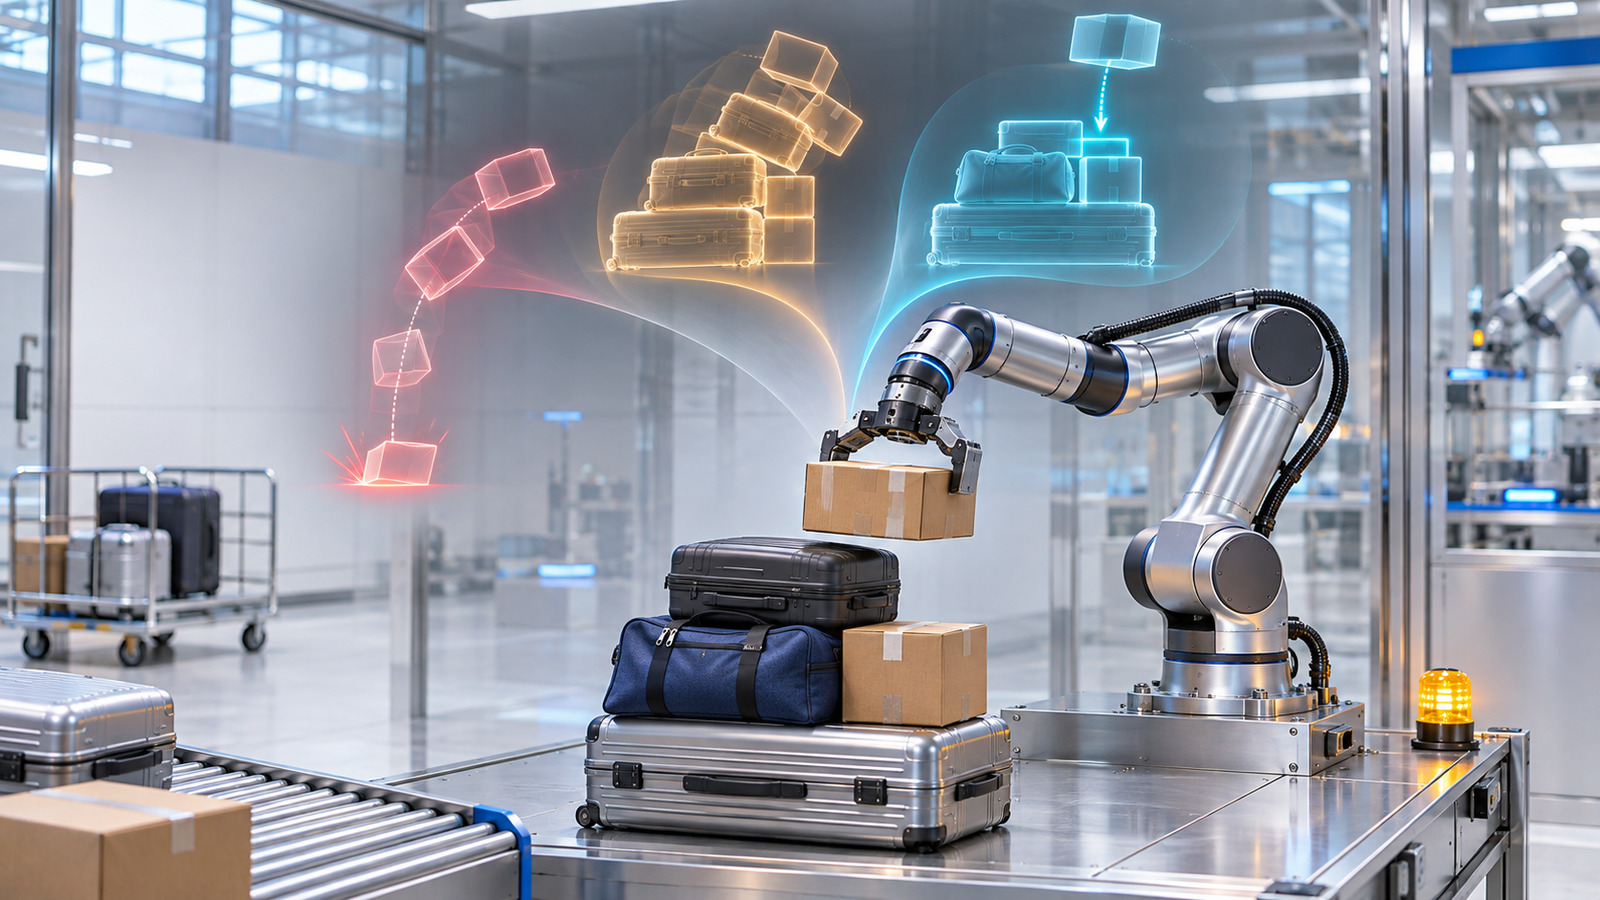
NTT’s physics-based world model tests robot actions before movement
NTT developed a physics-based world model that predicts candidate robot actions as video before execution and evaluates risks such as dropped objects or collapsing loads.
2 min readRead story


