
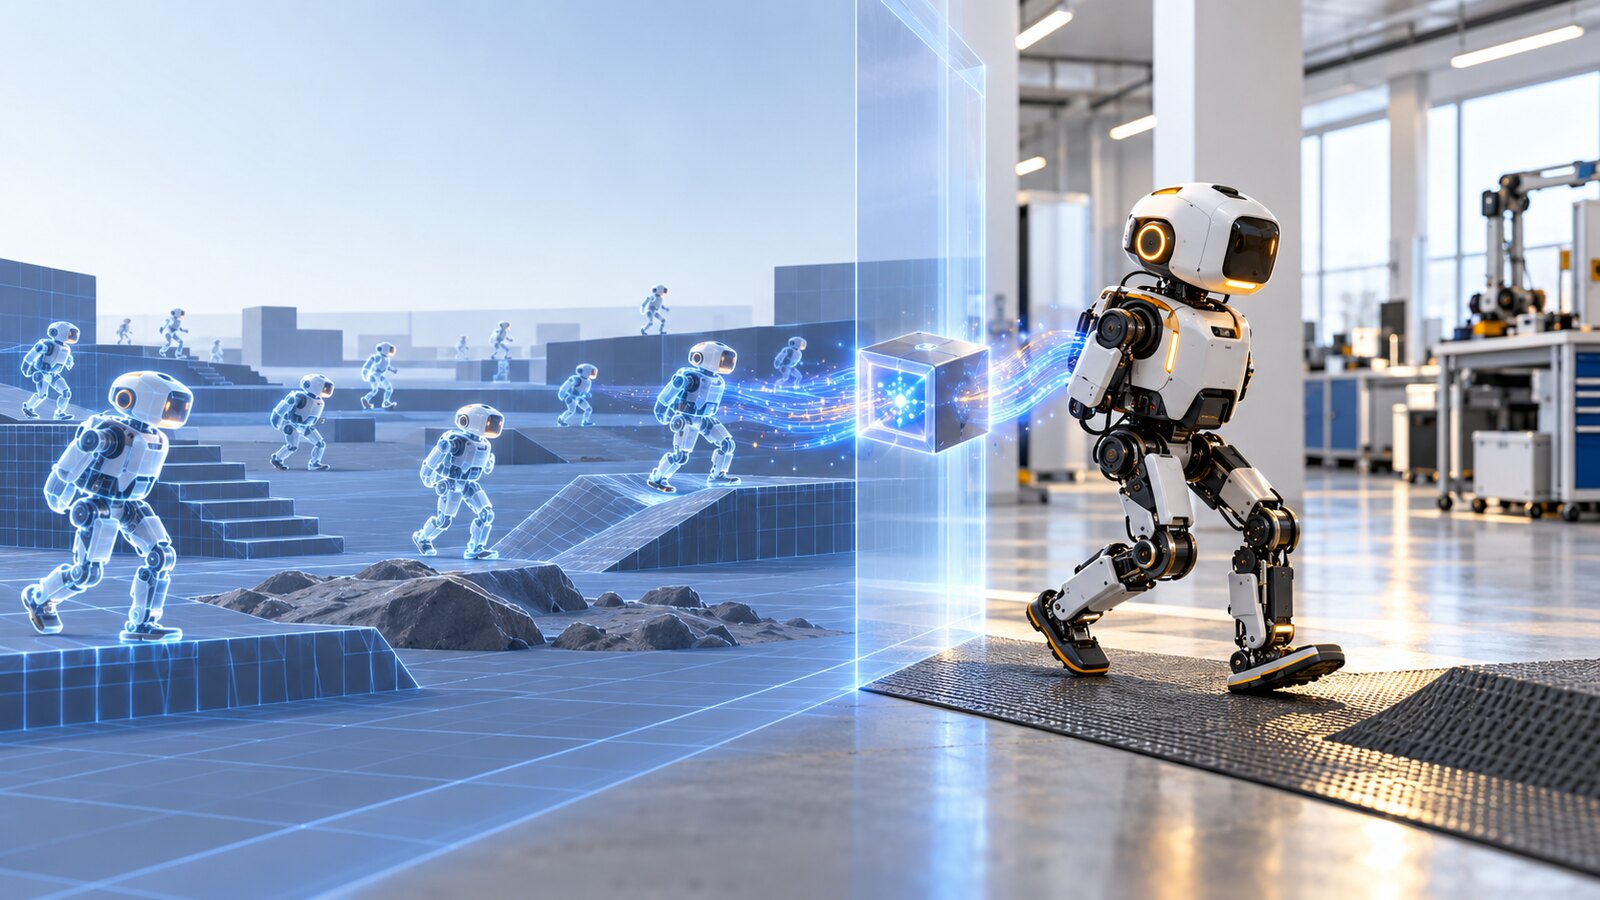
Microduck carries an Isaac Lab-trained walking policy onto a real robot
NVIDIA and Hugging Face published an open workflow that trains Microduck’s walking policy in parallel simulation with Isaac Lab 3.0 and exports it through ONNX for deployment on the physical robot.
2 min readRead story


