
Microduck carries an Isaac Lab-trained walking policy onto a real robot
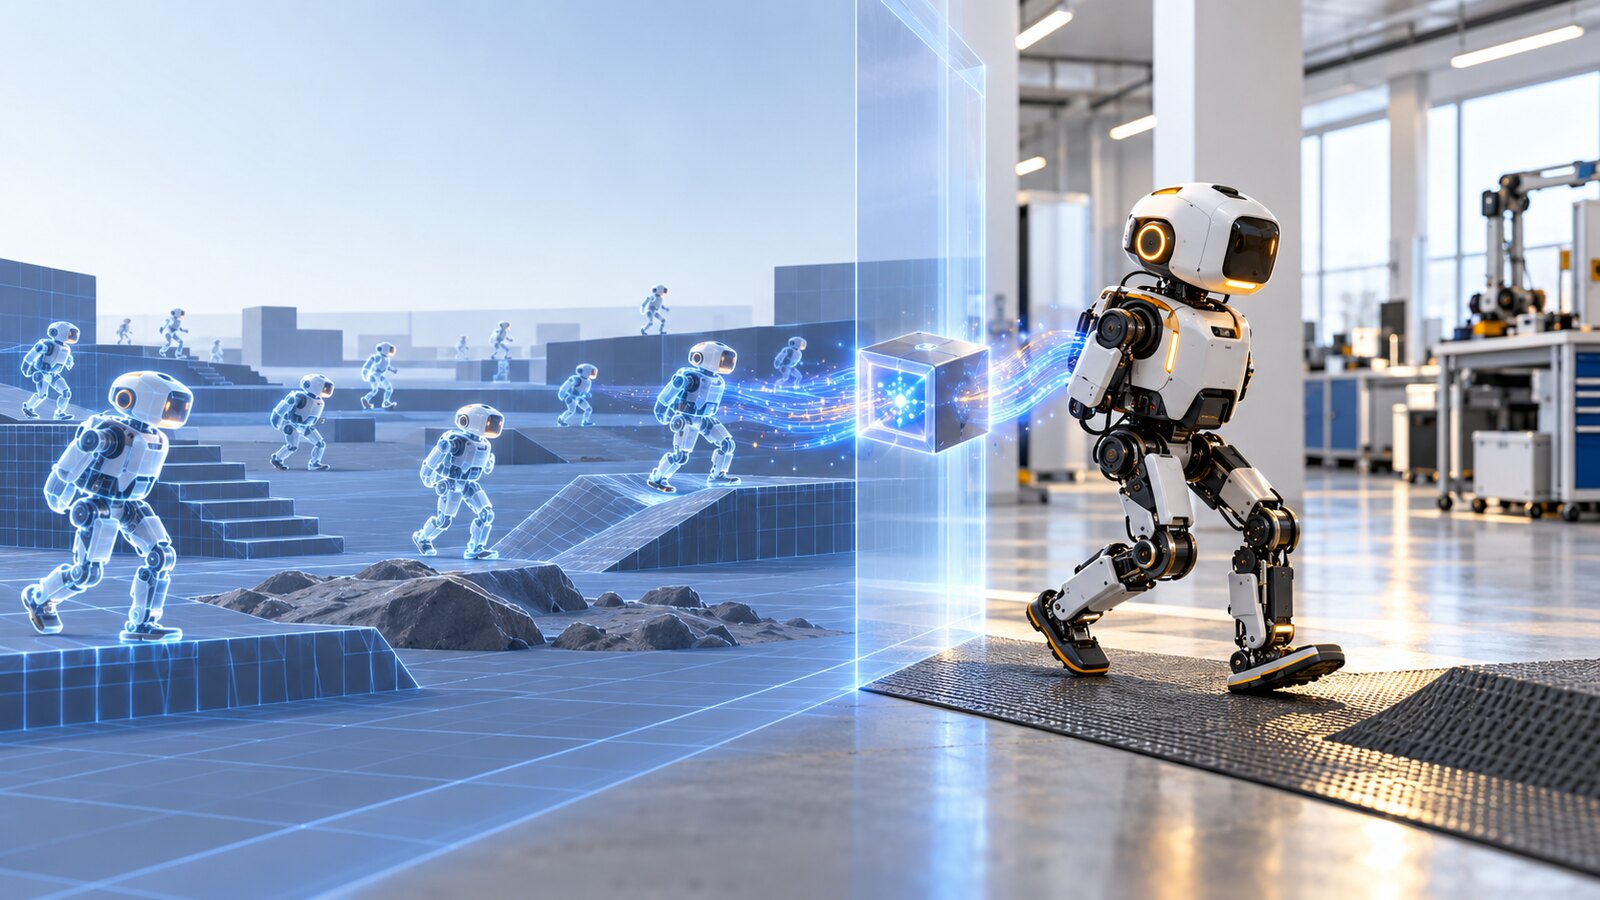
NVIDIA and Hugging Face published an open workflow that trains Microduck’s walking policy in parallel simulation with Isaac Lab 3.0 and exports it through ONNX for deployment on the physical robot.
AT A GLANCE
Key points
- The walking policy is trained in parallel simulation with Isaac Lab 3.0 and Newton
- It can be exported as TorchScript and ONNX and loaded onto the physical Microduck
- Hugging Face Hub and Microduck Arena support sharing and comparison
What is changing?
NVIDIA and Hugging Face published an end-to-end sim-to-real workflow for the affordable, open-source bipedal Microduck robot on October 21. Developed by Pollen Robotics and Hugging Face, the robot is trained in simulation with NVIDIA Isaac Lab 3.0 and Newton before the same policy is transferred to physical hardware.
The ready-made Microduck task packages the robot model, scene, observations, actions, rewards, and domain randomization. Thousands of flat- and rough-terrain environments can run in parallel on one GPU. NVIDIA says the example configuration reaches up to 1.25 million steps per second with rough terrain and a backlash model; that figure applies to the provider’s stated setup.
The trained walking policy is evaluated in simulation and then exported as TorchScript and ONNX files. The robot runtime can load the ONNX policy. Developers can share models on the Hugging Face Hub, compare them on common tasks in Microduck Arena, and extend the same foundation to perception, harder terrain, or new tasks.
Explore the original sources
Source date: 21 October 2026.
Published by AI Radar: 21 Oct 2026, 21:08 (Istanbul, UTC+3). Updated: 21 Oct 2026, 21:10.
FOLLOW THE TOPIC
Topics and tags
Share your discovery.
Send this story to a friend.
Reader comments
What do you think about this development? Share your experience or question. Comments are published after editorial approval.
Your name/nickname and comment become public if approved. Read: Privacy notice.




Loading comments…