
NVIDIA GR00T 2 learns robot skills from human video and transfers them across embodiments
NVIDIA’s open world action model GR00T 2 learns dexterous manipulation from human and robot data and can transfer the same skills across different robot bodies.
AT A GLANCE
Key points
- Trained with 100,000 hours of open-source egocentric human video.
- Completed 40 of 50 evaluated tasks at least once without task-specific demonstrations.
- Average success rose from 71% with one demonstration to 95% with five.
What is changing?
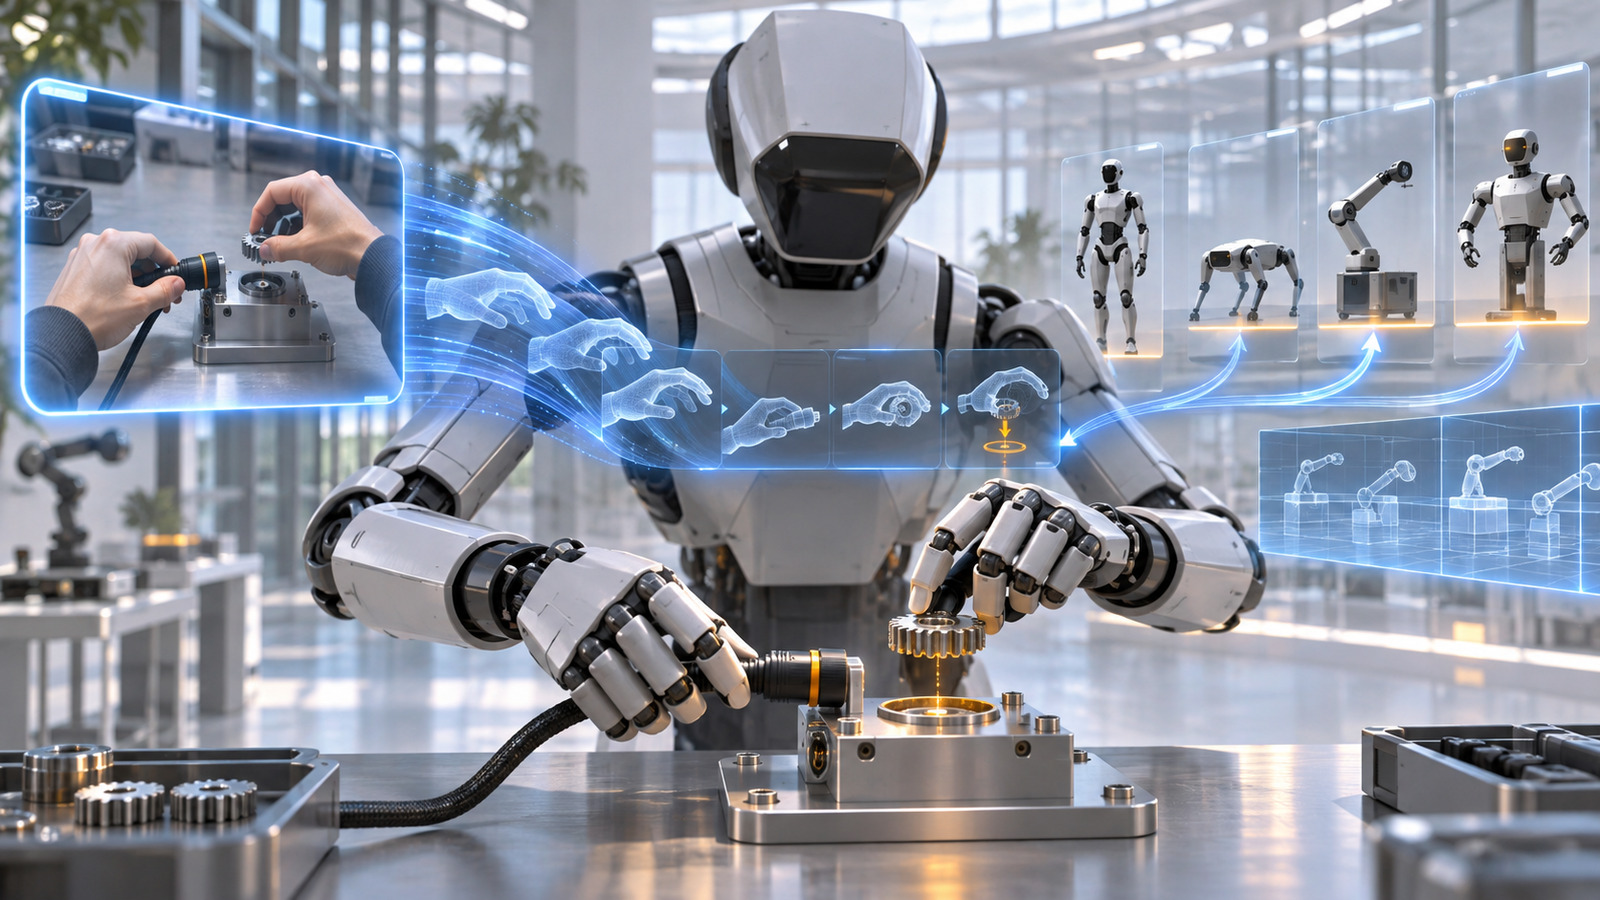
NVIDIA introduced GR00T 2 at the CoRL conference on November 9. Built on NVIDIA Cosmos, the open world action model was trained on robot and human data, including 100,000 hours of open-source first-person human video. It is designed to generalize precise tasks such as cable connection and small-part assembly across different robots.
According to NVIDIA, GR00T 2 completed 40 of 50 evaluated tasks at least once without task-specific demonstrations. Average success reached 71% with one demonstration per task and 95% with five. The model can transfer skills from human demonstrations and from one robot embodiment to another.
GR00T 2’s API lets AI agents sequence skills and recover from errors. Foxconn, Siemens, Nexuni and MicroAGI are testing the model for factory automation, laundry handling and cable swapping. Because these results come from NVIDIA’s own evaluations, independent testing is still needed.
Explore the original sources
Source date: 9 November 2026.
Published by AI Radar: 9 Nov 2026, 18:37 (Istanbul, UTC+3).
FOLLOW THE TOPIC
Topics and tags
Share your discovery.
Send this story to a friend.
Reader comments
What do you think about this development? Share your experience or question. Comments are published after editorial approval.
Your name/nickname and comment become public if approved. Read: Privacy notice.



Loading comments…