Runway releases Praxis‑1 world action model with open weights
Runway has made Praxis‑1, a 27-billion-parameter model designed to predict robot video and actions jointly, generally available with Apache 2.0 open weights.
1 min readRead story
CHOOSE YOUR FOCUS
NEWS FEED
Runway has made Praxis‑1, a 27-billion-parameter model designed to predict robot video and actions jointly, generally available with Apache 2.0 open weights.
NTT developed a physics-based world model that predicts candidate robot actions as video before execution and evaluates risks such as dropped objects or collapsing loads.
Hedra launched Model Factory for robotics, manufacturing, biology and defense teams. The platform combines GPU sandboxes, post-training, low-latency deployment and retraining from production evidence in one loop.
MemryX is targeting up to 10 times the peak AI compute and nearly 10 times the on-chip model memory of MX3 with the MX3+ accelerator, which is planned for 2027.
Google DeepMind's new vision-language-action model reports higher success rates than Gemini Robotics 2 across precise manipulation, contact-rich tasks and reliability on multiple robot embodiments.
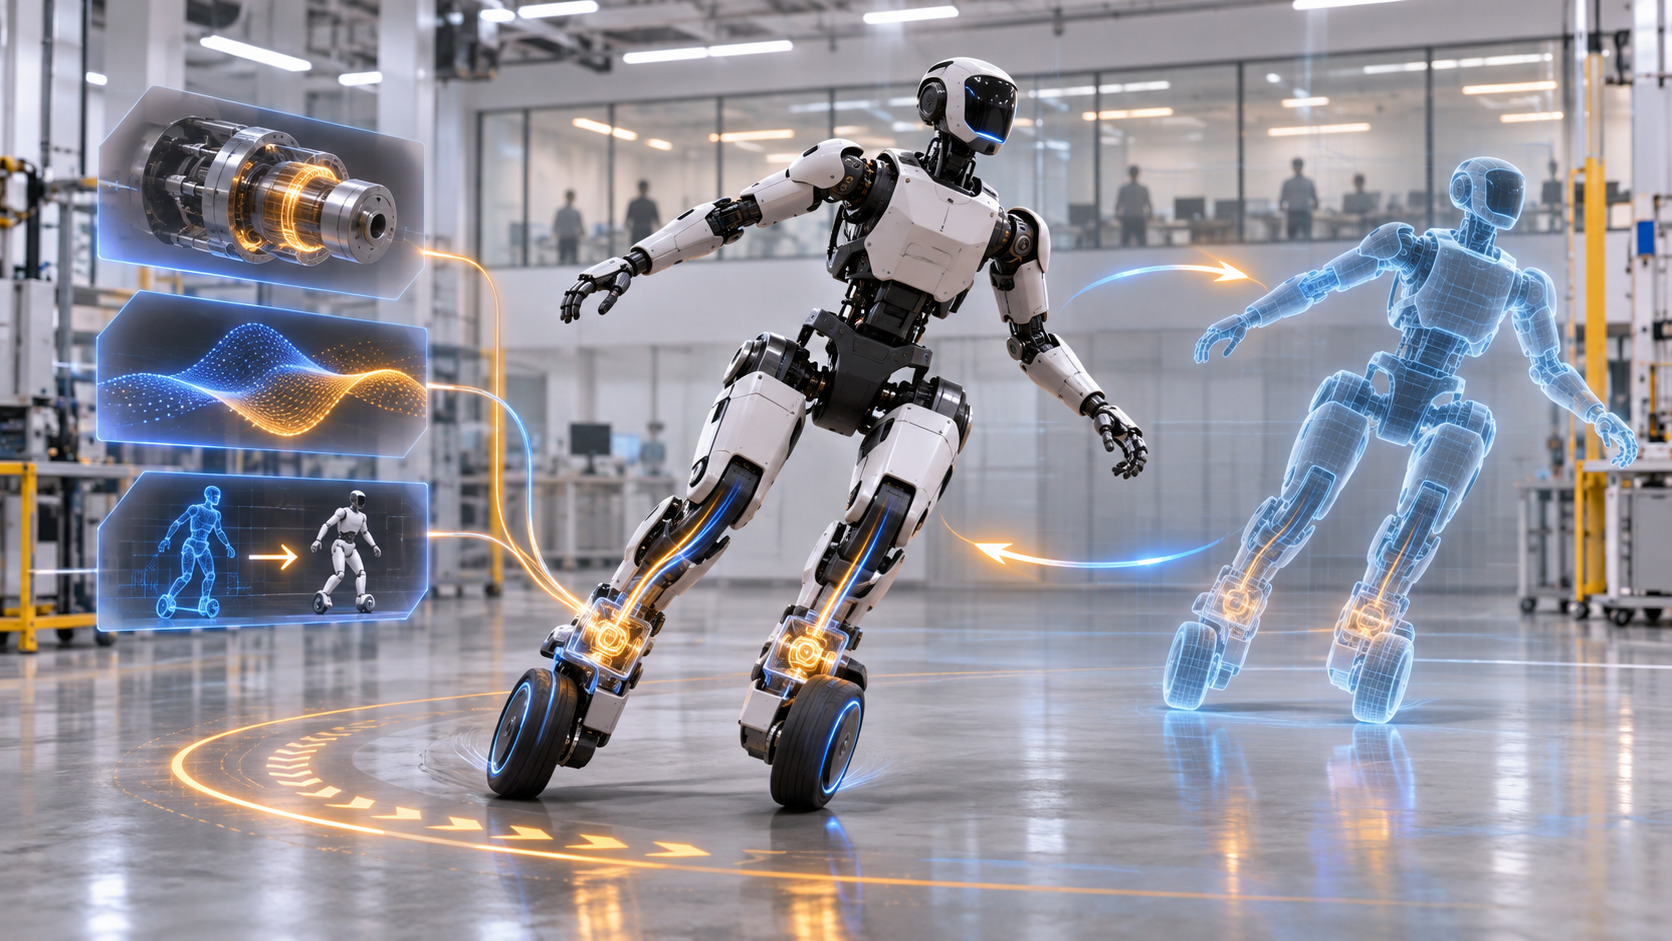
The wheeled Atlas is not a product; it is a research testbed for stressing actuators at high torque and speed and transferring a whole-body reinforcement-learning controller to real hardware.
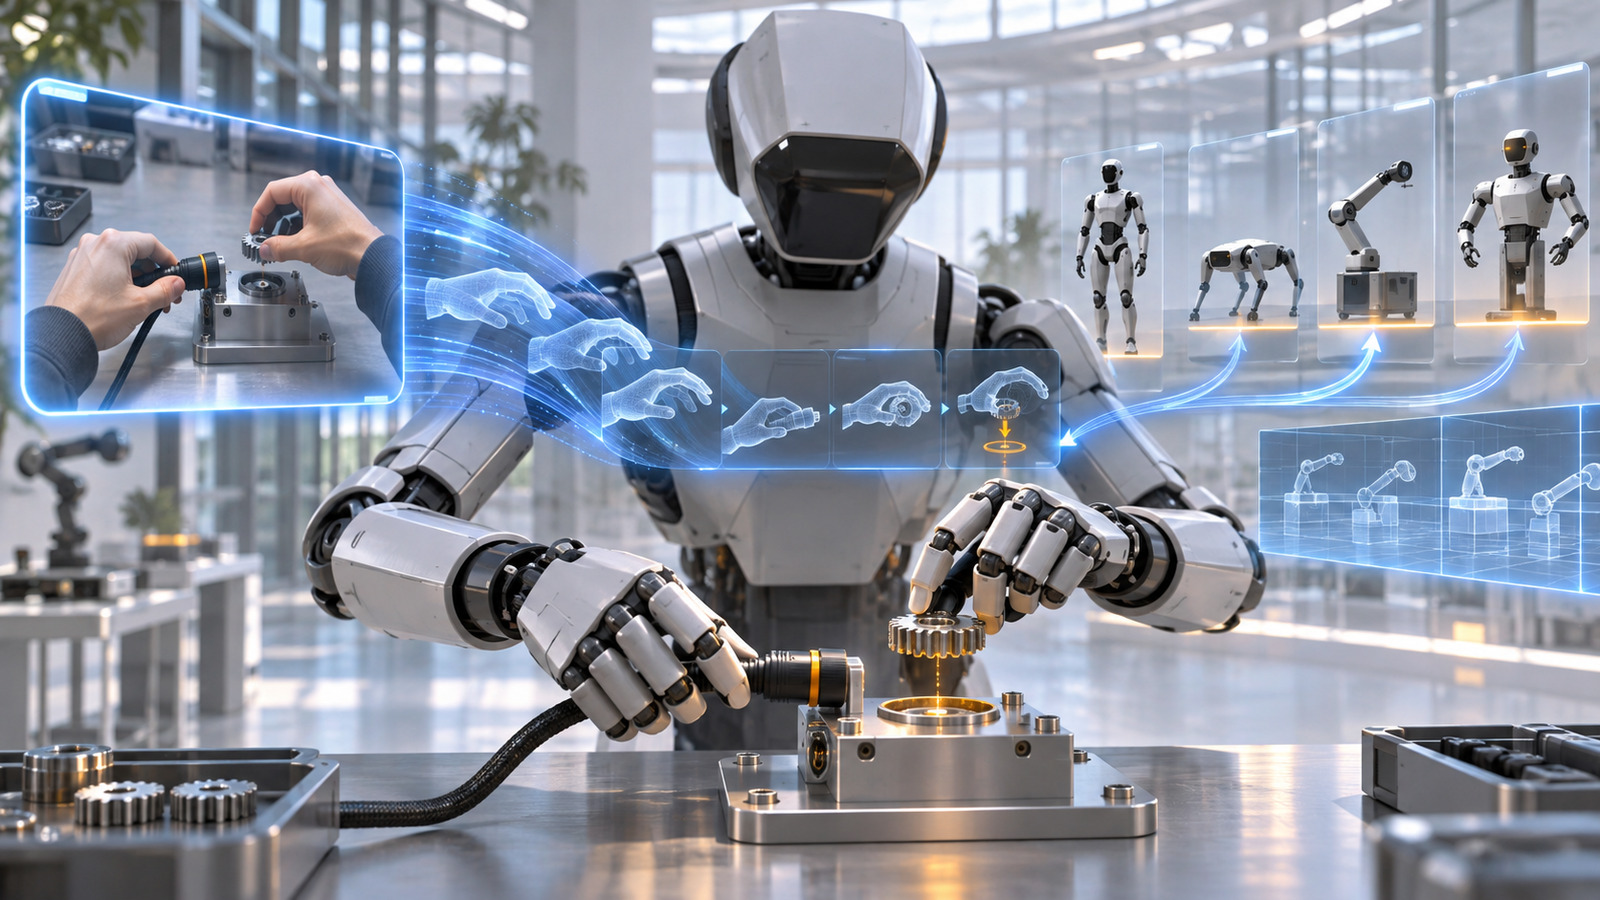
NVIDIA’s open world action model GR00T 2 learns dexterous manipulation from human and robot data and can transfer the same skills across different robot bodies.
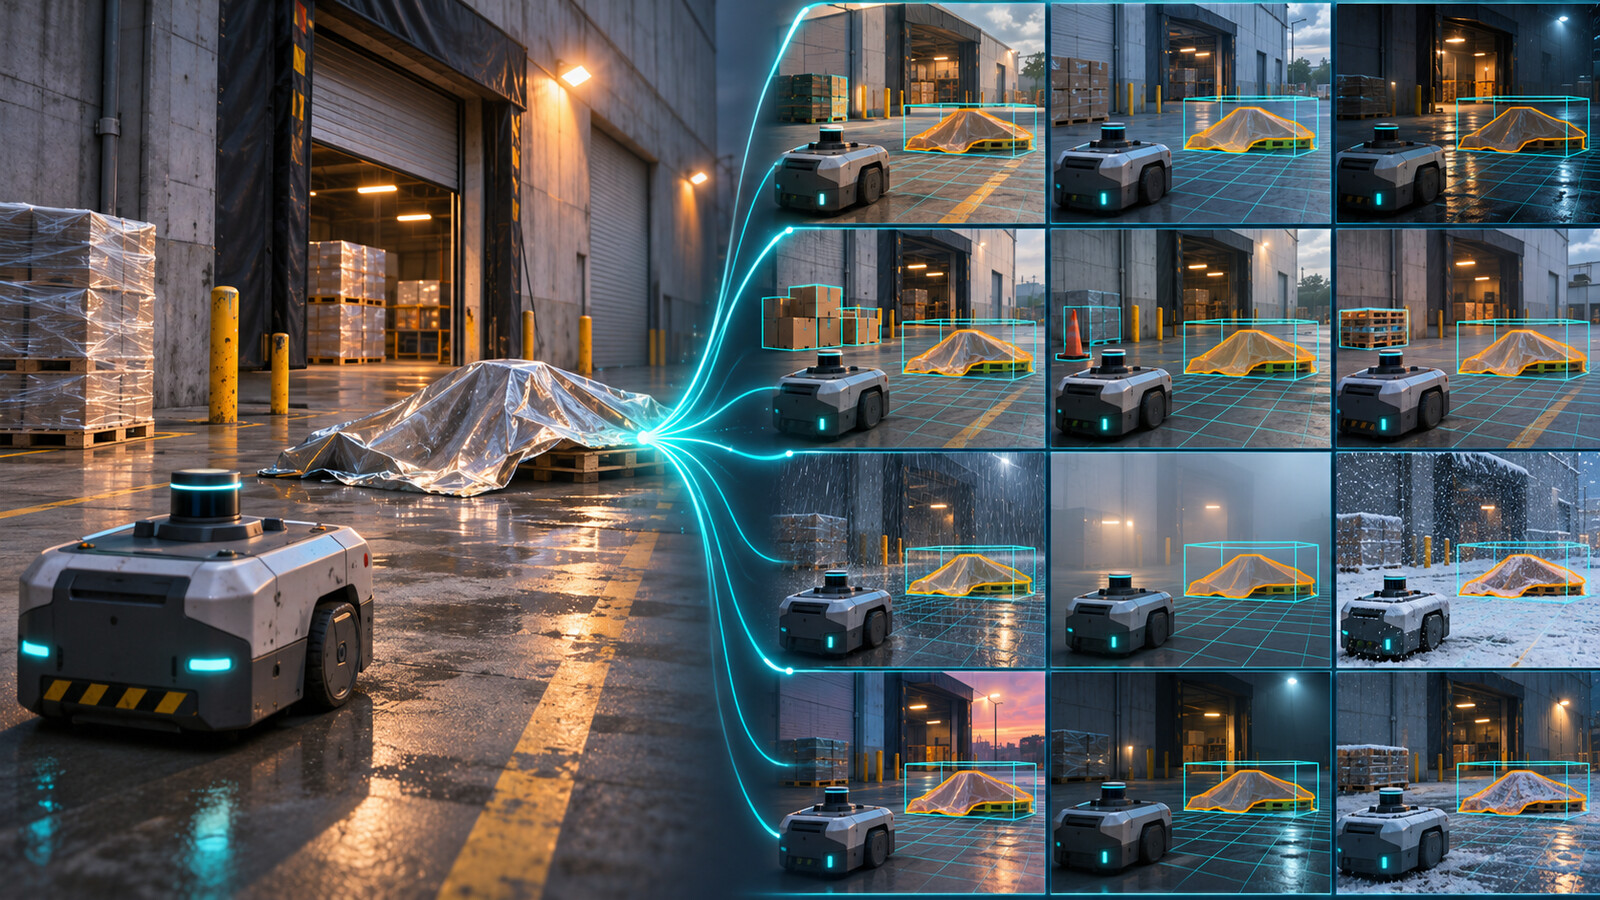
Physicl opened Studio in private beta, allowing physical AI teams to describe difficult scenes, generate controlled variations and receive exact labels for every frame.
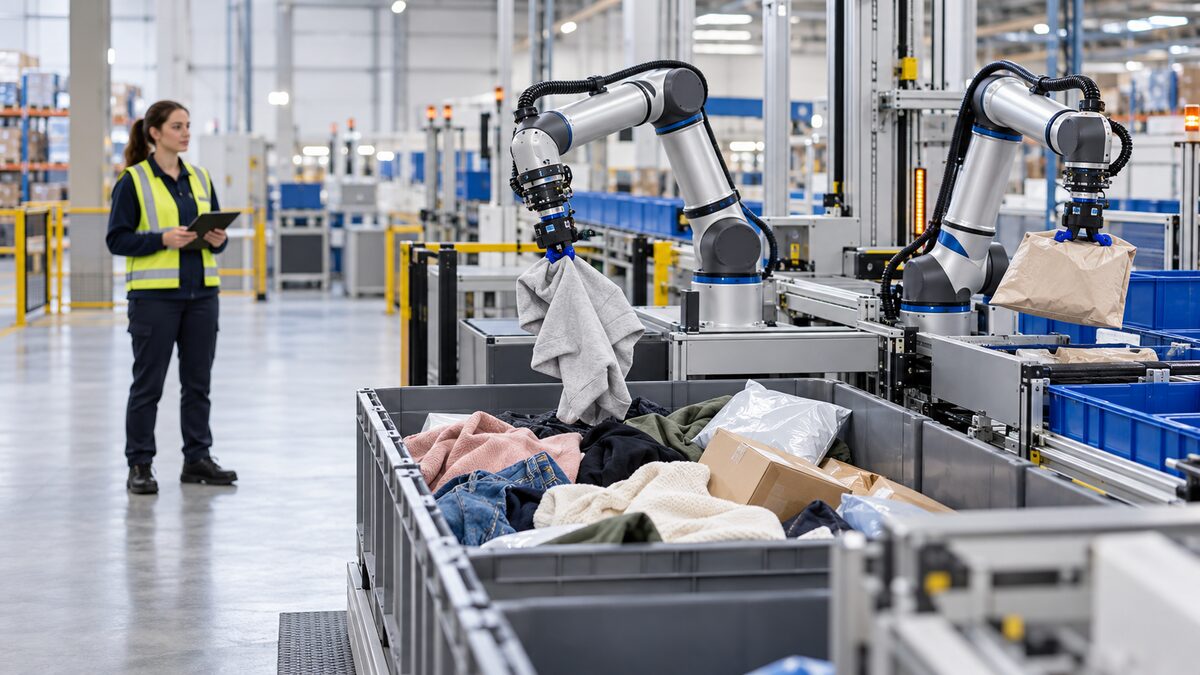
The partnership scales Sereact’s Cortex platform on Universal Robots arms for unstructured logistics tasks such as returns handling and piece-picking.
Physical AI Launchables provides a catalog of tested simulation, data-generation, training, and evaluation templates for Isaac Sim, CARLA, MuJoCo, AlpaSim, and Cosmos 3.
NVIDIA and Hugging Face published an open workflow that trains Microduck’s walking policy in parallel simulation with Isaac Lab 3.0 and exports it through ONNX for deployment on the physical robot.
Laplace Intelligence is building interactive simulations and automated red-team agents to identify dangerous edge cases in physical AI systems before deployment.
BEYOND THE HEADLINE
Every story includes a concise summary, its creative workflow implications and original sources. Explore official demos and examples alongside the news.
Our editorial approach@airadarhaber
Fresh AI developments, dedicated visuals and product examples. Explore our posts and catch up in Stories.
Follow on Instagram


GRAPHIC. DIGITAL. MOTION.
Explore my graphic design, branding
and motion work.